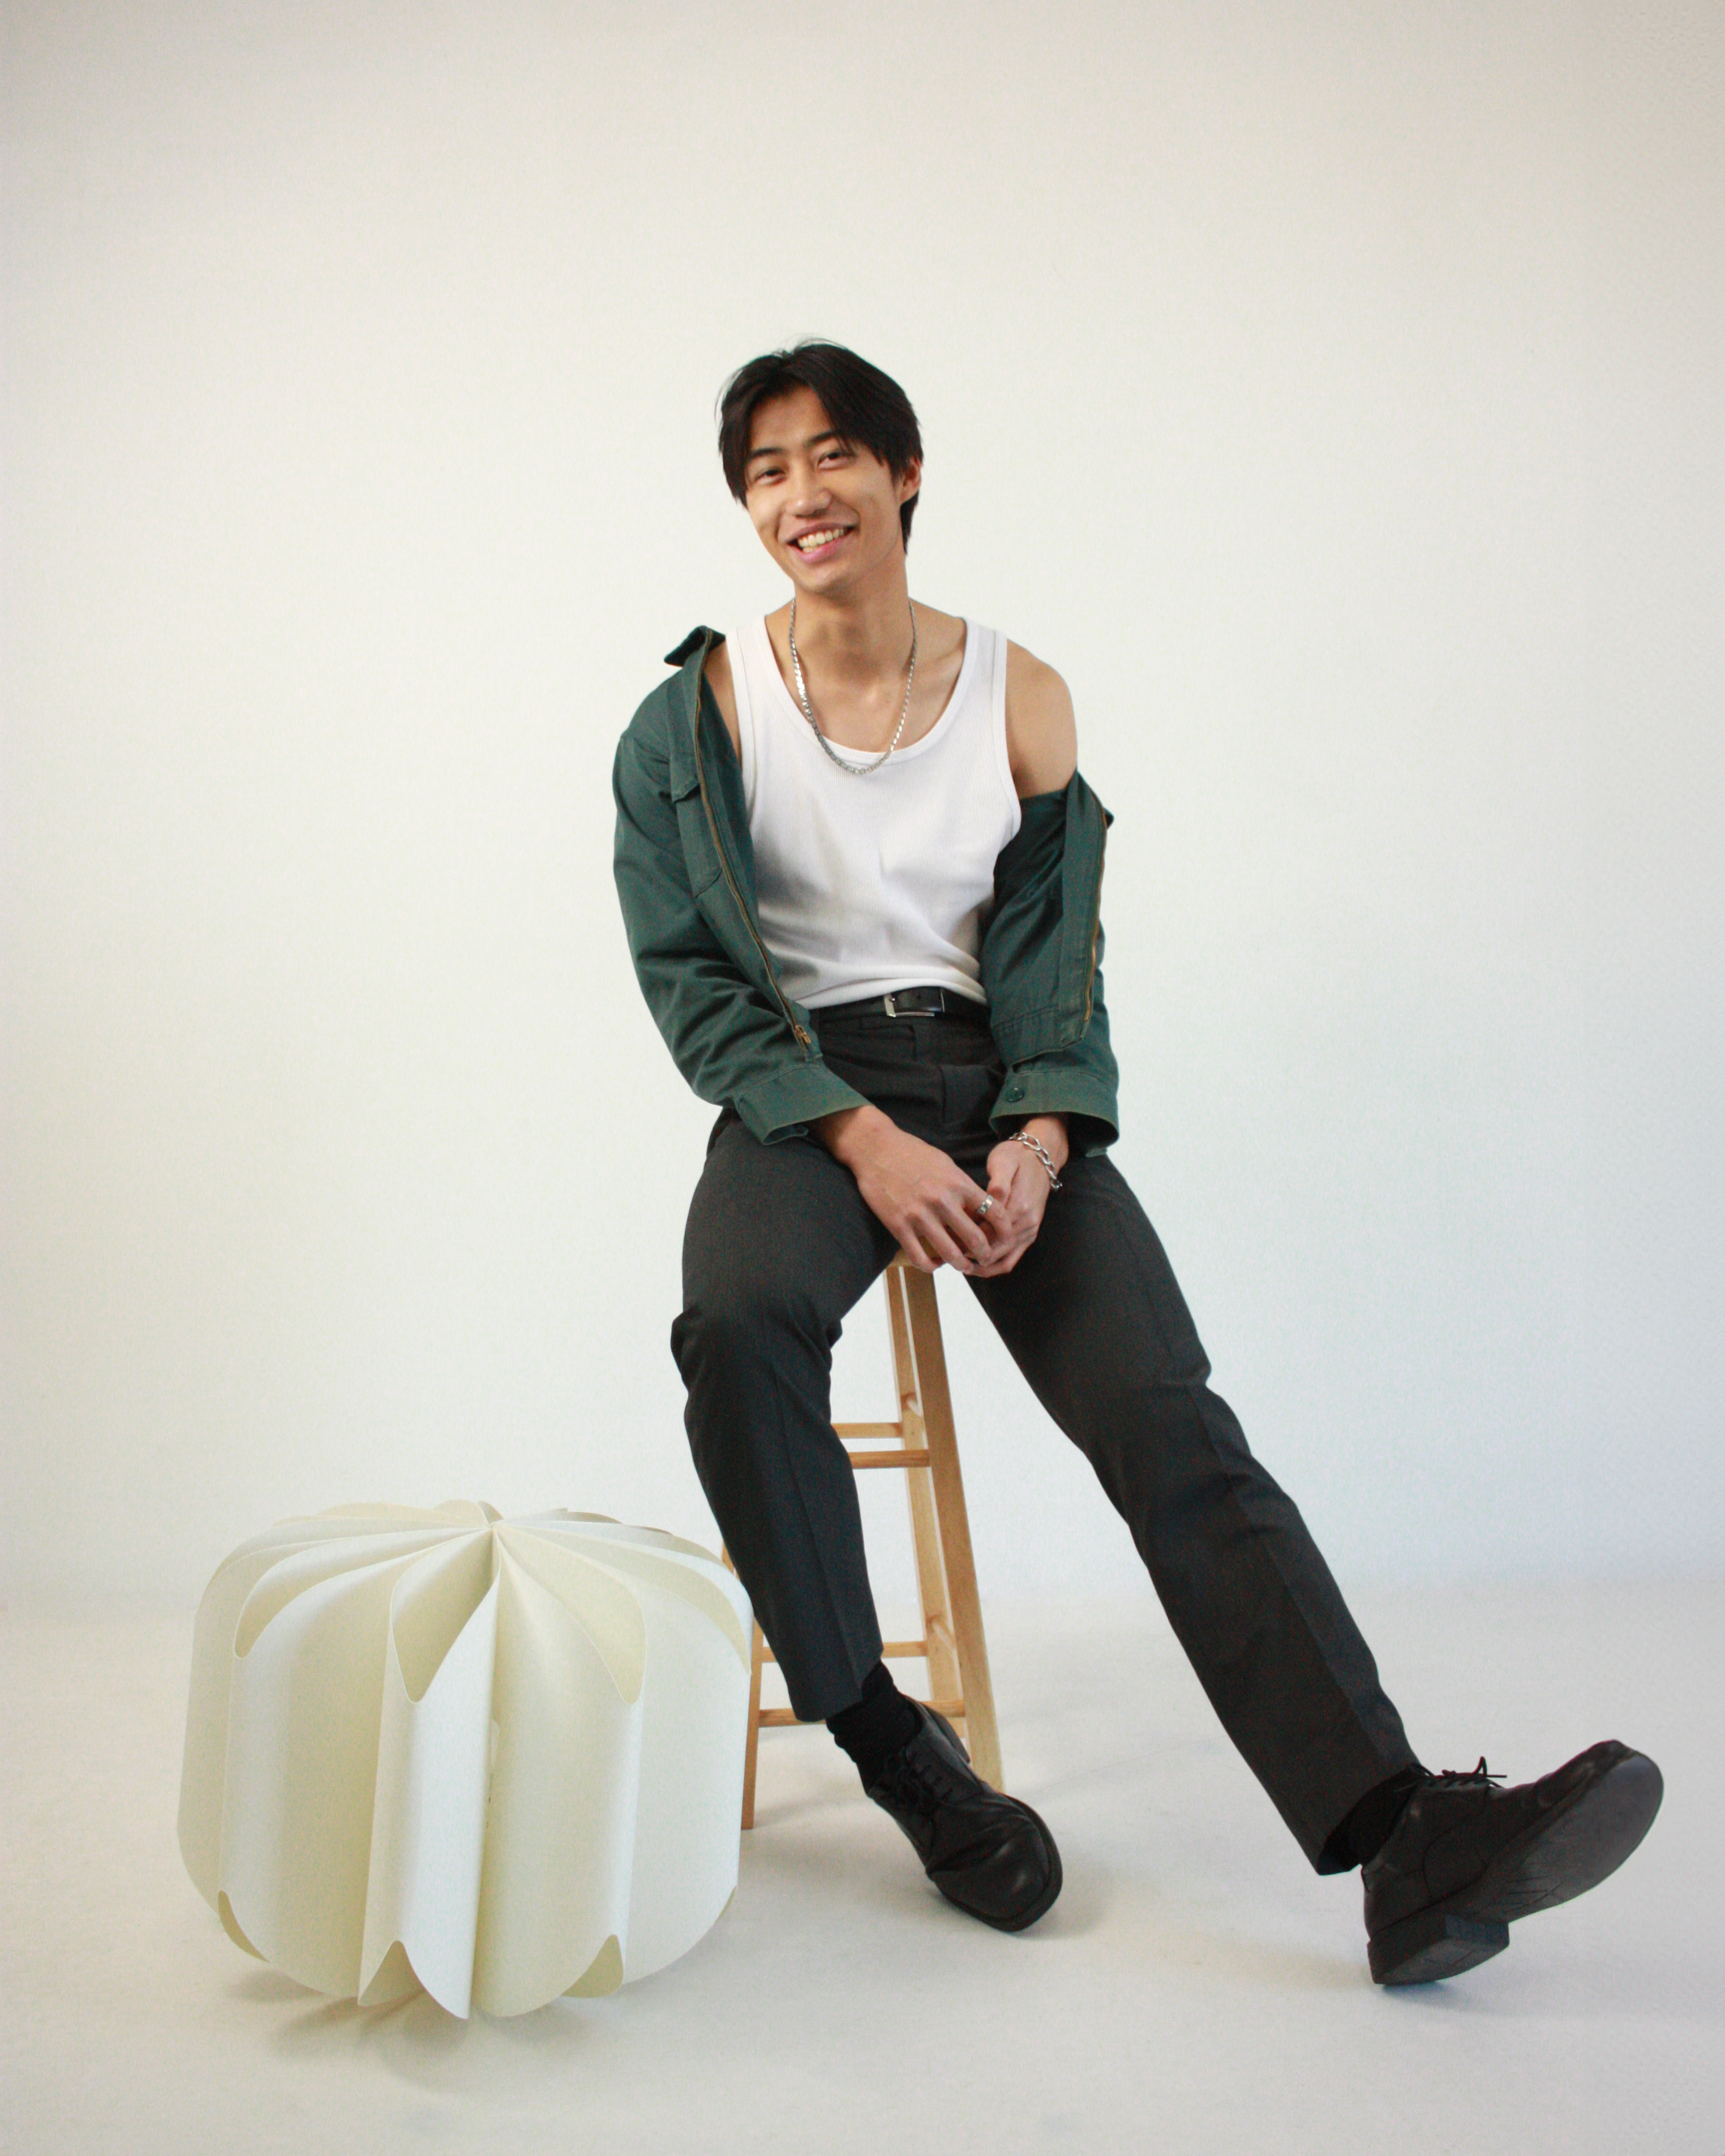
Hi, I'm Stephen Mock
I'm a robotics engineer with a strong systems engineering background: a "Swiss army knife" who works at the interface of hardware and software. In my free time I experiment with robotics and look for ways to build new systems into everyday life (IoT). My goal is to improve people's lives through robotics and get others excited about technology.
I'm most interested in robotics for consumer products, human-robot interaction (HRI), art and technology, and aerospace, but I'm always open to trying new things!
- Based in Los Angeles, CA
- Hometown: Boston, MA
- MBTI: ENTJ
Resume
My academic and professional experience. Please send me an email for a PDF version of my resume!
Academic Experience

Master's of Science in Mechanical Engineering
Georgia Institute of Technology (Atlanta, GA)
- Concentration in Robotics and Automation
- Georgia Tech Faculty Honors (2022)

Bachelor of Science in Mechanical Engineering
Georgia Institute of Technology (Atlanta, GA)
- Georgia Tech Faculty Honors (2017-2021)
Professional Experience
- EducationGeorgia Institute of Technology
 Relativity SpaceRobotics Engineer
 Motivo Engineering · Stratin EngineeringRobotics Engineering Consultant
 UCLA Biomechatronics LabR&D Engineer II
 Miso RoboticsTest Engineer
 NASA Jet Propulsion LaboratoryRobotics Mechanical Engineer
 iRobotMechanical Engineering Intern
 NASA Jet Propulsion LaboratoryMechanical Engineering Co-op
 SharkNinjaMechanical Engineering Intern
Robotics Engineer
Relativity Space: Long Beach, CA
Robotics system and mechatronics engineering for Horizon Manufacturing metal 3D printers.
Robotics Engineering Consultant
Motivo Engineering · Stratin Engineering: Los Angeles, CA
Systems engineering and R&D consulting for robotic products.
- Maintenance and assembly of animatronic robot systems
- Solicited system requirements from clients for aerospace, automotive, and consumer robotics applications including standards such as NFPA 70, DO-160 to enable tracability, risk reduction, and tracability.
- Developed system architecture for IoT robotic application to coordinate system interfaces between multiple stakeholder software stacks
- Integration and bring up for robotic prototypes involving Jetson Nano, perception, audio and lighting systems for client stakeholder demo
- Developed CAN-bus hardware drivers for control of 10+ LEDs and animation via web protocols
- Designed and delivered test systems to mitigate thermal cycle risk and enable software development in the field
- Taught entire company engineering fundamentals on V&V and extensible test design
R&D Engineer II
UCLA Biomechatronics Lab: Westwood, CA
Research and development for tactile-driven robots used in human-robot systems.
- Responsible engineer for system delivery of teleoperated HIL (human in the loop) bimanual robotic system with tactile sensors and neural haptics used for human-robot shared embodiment research
- Responsible engineer for system delivery of portable teleoperated HIL robotic system with gripper, tactile sensors, and neural haptics, presented at UN AI for Good 2025 conference to demonstrate robotics with touch
- Managed program execution of UCLA robotic system and portable demo, leading team of 8 and 6 respectively, while coordinating multi-institutional collaboration between four universities
- Released complete robotic system including hardware, software, requirements, interface control documents, GUI, Bill of Materials, and standard operating procedures, ensuring integration across university partners
- Designed and implemented ROS2-based HITL (Hardware-in-the-Loop) unit test framework, creating 200+ test cases to verify system functionality pre-deployment
- Worked with PhD students to implement advanced control algorithms and designed unit test framework to evaluate robot controller design within both simulation and hardware
- Developed robot hardware, including grippers, cable management solutions, and electronics
- Designed and implemented ROS2 software drivers including robot arms, grippers, motors, and tactile sensors
- Designed and implemented algorithms for hand mapping and stimulation using tactile sensors, neural haptics, and hand tracking devices to enhance shared autonomy experience
- Designed, managed, and trained students in proper hardware (PDM) and software (Git) release management systems, enabling effective multi-institute collaboration
Test Engineer
Miso Robotics: Pasadena, CA
Systems engineering development and testing for future robotic kitchen solutions.
- Designed and developed two HITL test fixtures for root cause analysis and durability testing of a robotic gripper and 6DoF robotic arm, leveraging ROS1, rosserial, and embedded systems
- Conducted testing and contributed to the design of robotic arm peripherals, focusing on field reliability and food safety compliance
- Designed end-to-end test framework connecting hardware to cloud, automating DUT traceability, JIRA Xray issue reporting, and structured data aggregation in Amazon Athena
Robotics Mechanical Engineer
NASA Jet Propulsion Laboratory: Pasadena, CA
Extreme Environment Robotics Group (347C), supporting Mars Sample Return (MSR) Capture Contain Return System (CCRS).
- Cognizant V&V Engineer, 2nd gen MSR Prototype End Effector Testbed
- Oversaw and conducted verification and validation (V&V) to deliver testbed system
- Ensured functional testbed operations by developing and conducting 8 detailed procedures
- Designed and assembled laser nest assembly to characterize testbed stiffness using 7 single-axis lasers
- Created MATLAB script for stiffness characterization using coordinate frame transformations and inverse kinematics to track deformation in 6DoF
- Mechanical Support Engineer, 3rd gen MSR End Effector TVAC Testbed
- Conducted bearing and bolt hand-calculations for component sizing using JPL flight design principles
- Contributed to testbed heat loss calculations and design of a redundant heating system with thermal controllers, heaters, and thermocouples for temperature-critical components
- Software Development Support Engineer, 4th gen MSR End Effector TVAC Testbed
- Verified redundant heating system concept of operations by assembling and testing thermal system benchtop prototype for 15 different fault scenarios
- Wrote Python drivers for asynchronous interfacing with 16 thermal controllers and 3 power supplies using Async IO Modbus TCP, VISA TCP/IP, and USB
- Designed and tested ROS2 software architecture for thermal controller and power supply telemetry logging and service calls for operator interfacing
- Deployed testbed and conducted MATLAB data analysis of testbed fault protection response time
Mechanical Engineering Intern
iRobot: Bedford, MA
Supported development of future robotic vacuums, docks, and test fixtures.
- Designed and assembled 7 benchtop prototypes of new robot dock product with 30+ components for software testing
- Designed and tested a modular wheel traction fixture to improve tread effectiveness for a new robot product using Creo and top-down assembly modeling
- Assisted with prototype build, root cause investigation and free body analysis to improve dock product
Mechanical Engineering Co-op
NASA Jet Propulsion Laboratory: Pasadena, CA
Extreme Environment Robotics Group (347C), supporting Mars Sample Return (MSR) Capture Contain Return System (CCRS), Mars Sample Return Handling (MSRH).
- Conceptualized, procured, and assembled automated testbed ($100K) to characterize and evaluate misalignment error for MSR robotic arm end effector in 6 degrees of freedom (DOF)
- Designed second iteration testbed ($500K) to undergo thermal vacuum requirements (-70C, high vacuum) and higher load/stroke operations
- Created MATLAB simulation for inverse/forward kinematics for MSR Robotic Arm testbed operations
- Wrote code to minimize MSR Robotic Arm link length and joint torques, perform basic path planning and clearance/tolerance checking
- Designed custom tools to mount, cut, extract Mars samples from tubes when returned to Earth
- Co-authored IEEE Aerospace paper on decontamination process for MSRH
Mechanical Engineering Intern
SharkNinja: Needham, MA
Prototyped new Shark Robotic Vacuums in the Advanced Development group.
- Implemented solutions to improve robot docking; design was manufactured and sold
- Performed root cause analysis to apply mechanical solutions for robots going to mass production
Skills
A snapshot of my skill graph: every skill in my engineering wiki, rated from 1 (aware) to 5 (expert).
Projects
Things I've built. Open one for photos and the full story.
 Featured 7 3
Sample Project (test, delete me)
A test project with random photos to preview the new project pages.
LED LAMP
A 3D-printed LED lamp with a single-wall printed diffuser shell.
Twitch Cam V2
A portable redesign of TwitchCam, built around a Raspberry Pi and a servo HAT.
TwitchCam V1
A pan/tilt camera robot that Twitch chat controls live, running ROS 2 on a Raspberry Pi with an ESP32 over micro-ROS.
Interests
Here are my core research interests!
Consumer Products
Developing products for everyday consumers
Aerospace
Exploring space and extreme environments
Human Robot Interaction (HRI)
Defining how humans and robots work together
Internet of Things (IoT)
Connecting everyday systems to the internet
Interactive Media
Linking humans with technology for new media experiences
Fashion Technology
Fusing fashion and technology to develop novel wearable devices
Music
Producing, arranging, and listening to new music
Content & Education
Creating engaging content to teach and inspire the next generation
Portfolio
Here is a portfolio showcasing some of my previous work!